02 / Orbit-5 / Mechanical · Robotics
5-DoF cinematography robotic arm
I designed the arm subsystem and interfaces within a team-developed, 5-DoF cinematography concept.
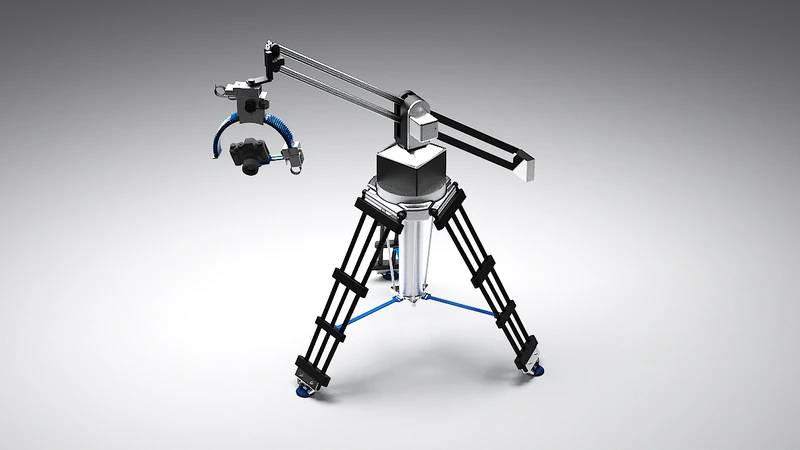
Orbit-5: the complete team-designed 5-DoF cinematography concept, shown as a CAD render. My contribution focused on the arm subsystem and its interfaces.
Enlarge CAD render01 / My contribution
Arm architecture & interfaces.
I designed the structural arm connecting the rotary base to the team’s camera-support assembly.
The challenge was to preserve shaft alignment while fitting the gear train, motor mounts, counterweight attachment and assembly access into the hub.
- I developed the U-mount, cover plates, arm sheath and motor enclosure, coordinating their mounting and shaft interfaces.
- I compared a simpler lightweight arrangement with a more enclosed structural concept, then refined access and clearances with teammates.
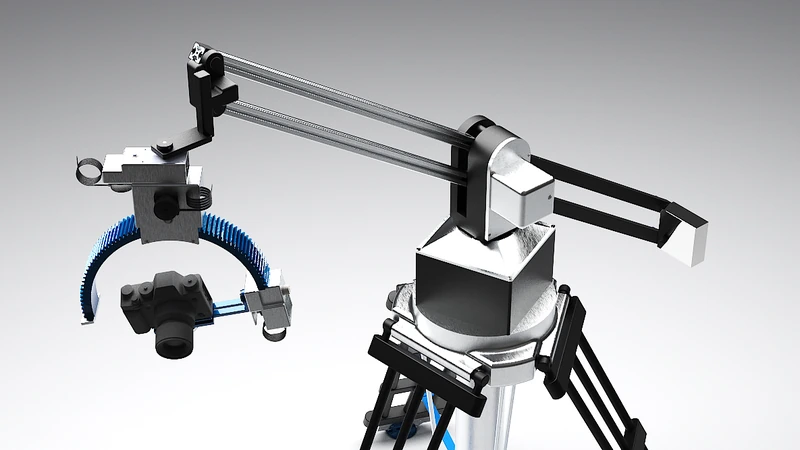
The arm structure, base interface, rear extension and camera support place my U-mount, sheath, counterweight and mounting-interface work within the complete team concept.
Enlarge CAD render02 / Team mechanism context
The camera-support mechanism.
The team’s camera-support mechanism provides three camera-head axes alongside arm elevation and base rotation. I coordinated the adjoining shaft, fastener and mounting interfaces for my arm subsystem.
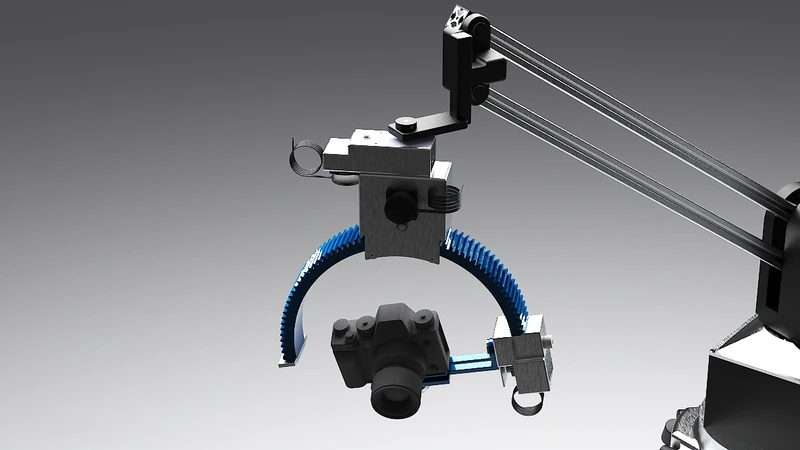
Camera-support assembly and curved gear interface, shown as team-mechanism context.
Enlarge CAD render03 / Team transmission context
Counterbalance & transmission.
I used the counterweight arrangement to offset the camera-support load. Its attachment and mass placement affect elevation-axis torque, so I considered counterbalance geometry alongside actuator sizing.
The team’s base concept uses a custom 30:1 cycloidal reducer. This exploded view shows its component arrangement and the interfaces around the rotary base.
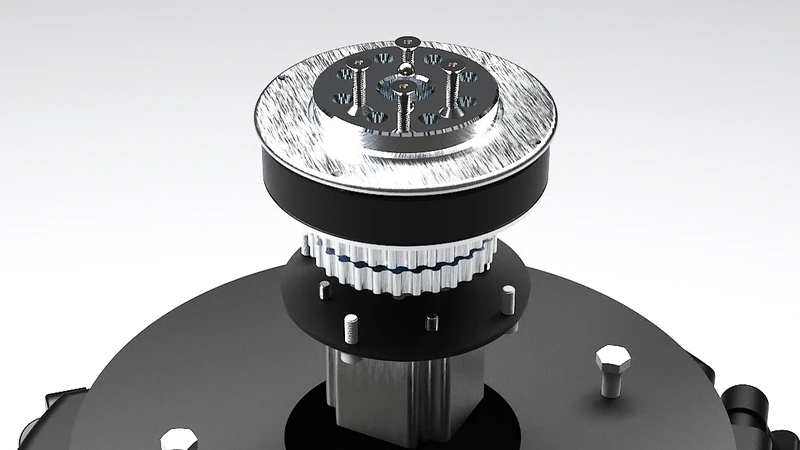
Exploded CAD view of the custom cycloidal-drive assembly and its component arrangement.
Enlarge CAD renderI coordinated shaft support, gear placement and motor mounting within the U-mount and cover plates. The arm sheath connects those interfaces to the extrusion and counterweight attachment.
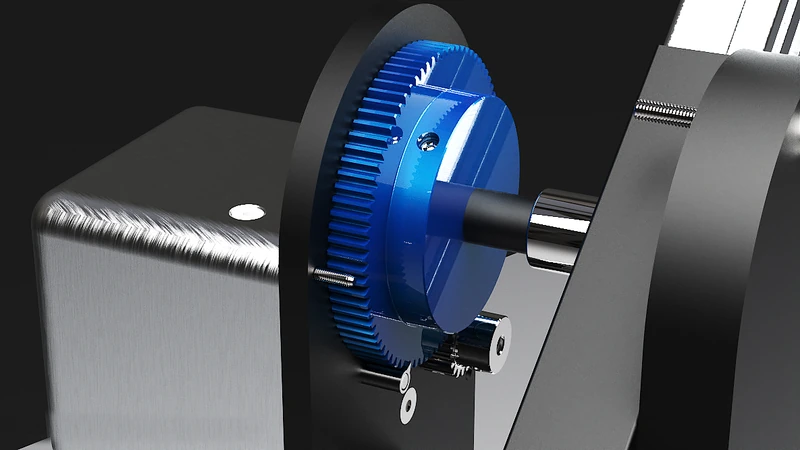
Gear train and shaft interfaces in the team assembly, adjoining the U-mount, cover plates and arm-sheath interfaces of my subsystem.
Enlarge CAD render04 / Team mechanism context
Camera-side gear & actuator detail.
I packaged the arm actuator in a motor enclosure, coordinating the covers, assembly access and clearance for a proposed stop mechanism. The camera-side close-up shows the adjoining team mechanism.
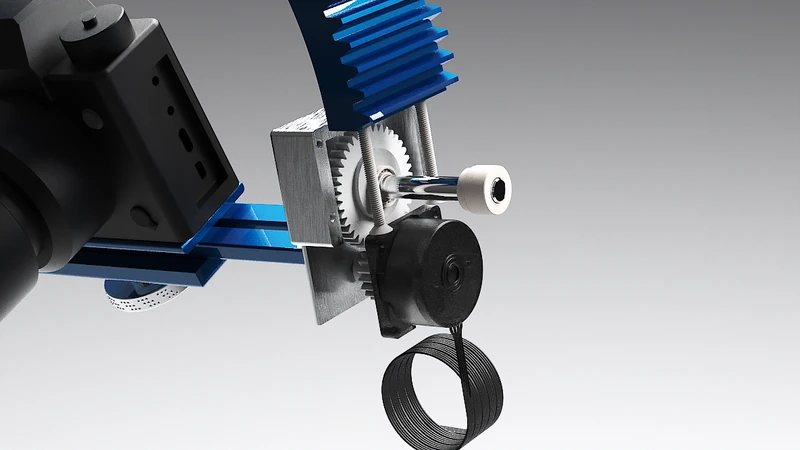
Close-up of the camera-side gear, actuator, and adjacent mounting arrangement.
Enlarge CAD render05 / Design reasoning & status
A concept and its next iteration.
I developed Orbit-5 as a conceptual CAD design supported by analytical sizing, geometry checks and component information.
Next iteration
My next iteration would reconcile actuator sizing and the final reduction, then refine the counterbalance and packaging to reduce the CAD mass, which exceeded the portability target.
Next project / 03