08 / Software · Robotics
Traffic sign recognition
I built a YOLOv11 detection and PyTorch classification pipeline for traffic-sign recognition.
Screen-recorded inference on daytime and nighttime road scenes.
Predicted sign regions, labels and confidence annotations update as each scene progresses.
- Training images
- 50k+ Mapillary Traffic Sign Dataset
01 / The brief
Localize first, classify second.
I used YOLOv11 to detect candidate sign regions and a custom PyTorch CNN to classify them. Separating the stages made dataset preparation and class imbalance explicit parts of the pipeline.
02 / My contribution
Dataset preparation and reproducible runs.
I trained on 50k+ Mapillary Traffic Sign Dataset images, cleaned labels and applied targeted augmentation for class imbalance. I used Docker/CUDA workflows for reproducible training and validation, and tested webcam and vehicle-captured video under day/night conditions.
03 / Evidence & scope
Actual predictions on street imagery.
These inference frames show the pipeline’s predicted boxes, labels and confidence annotations on street scenes.
Inference output
03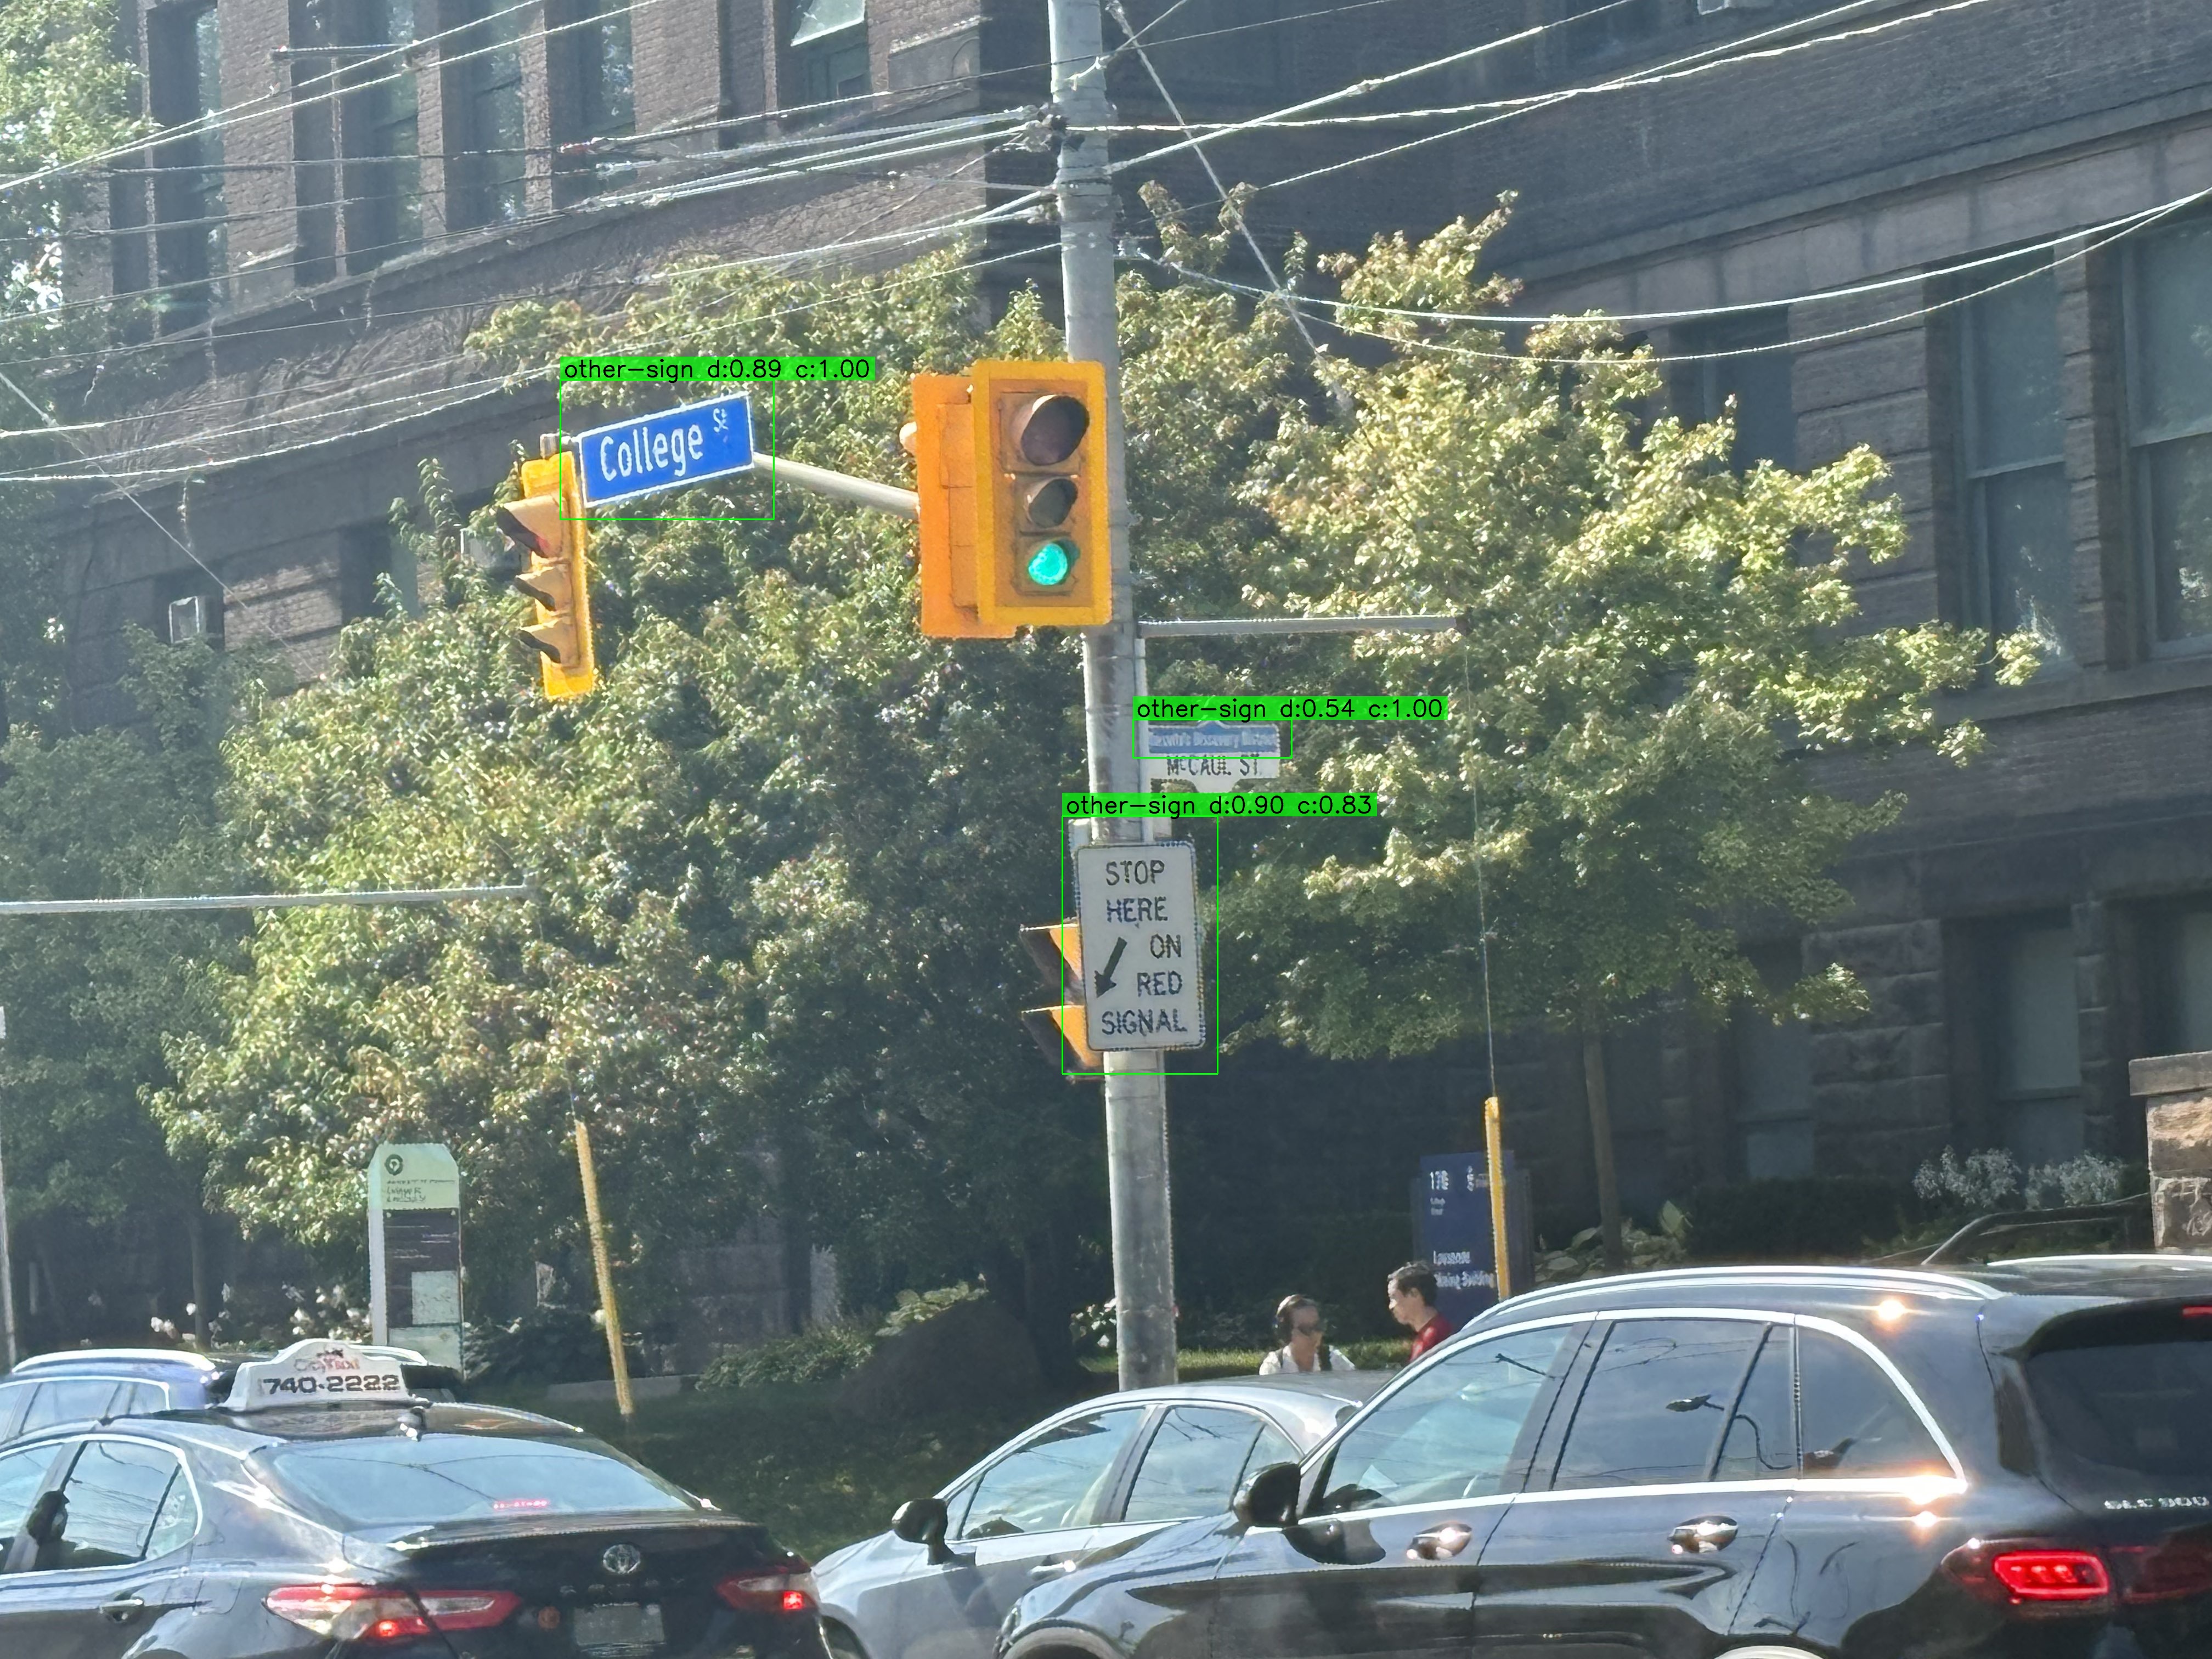
Actual inference output. Green boxes and labels show the model’s predictions on street imagery.
View original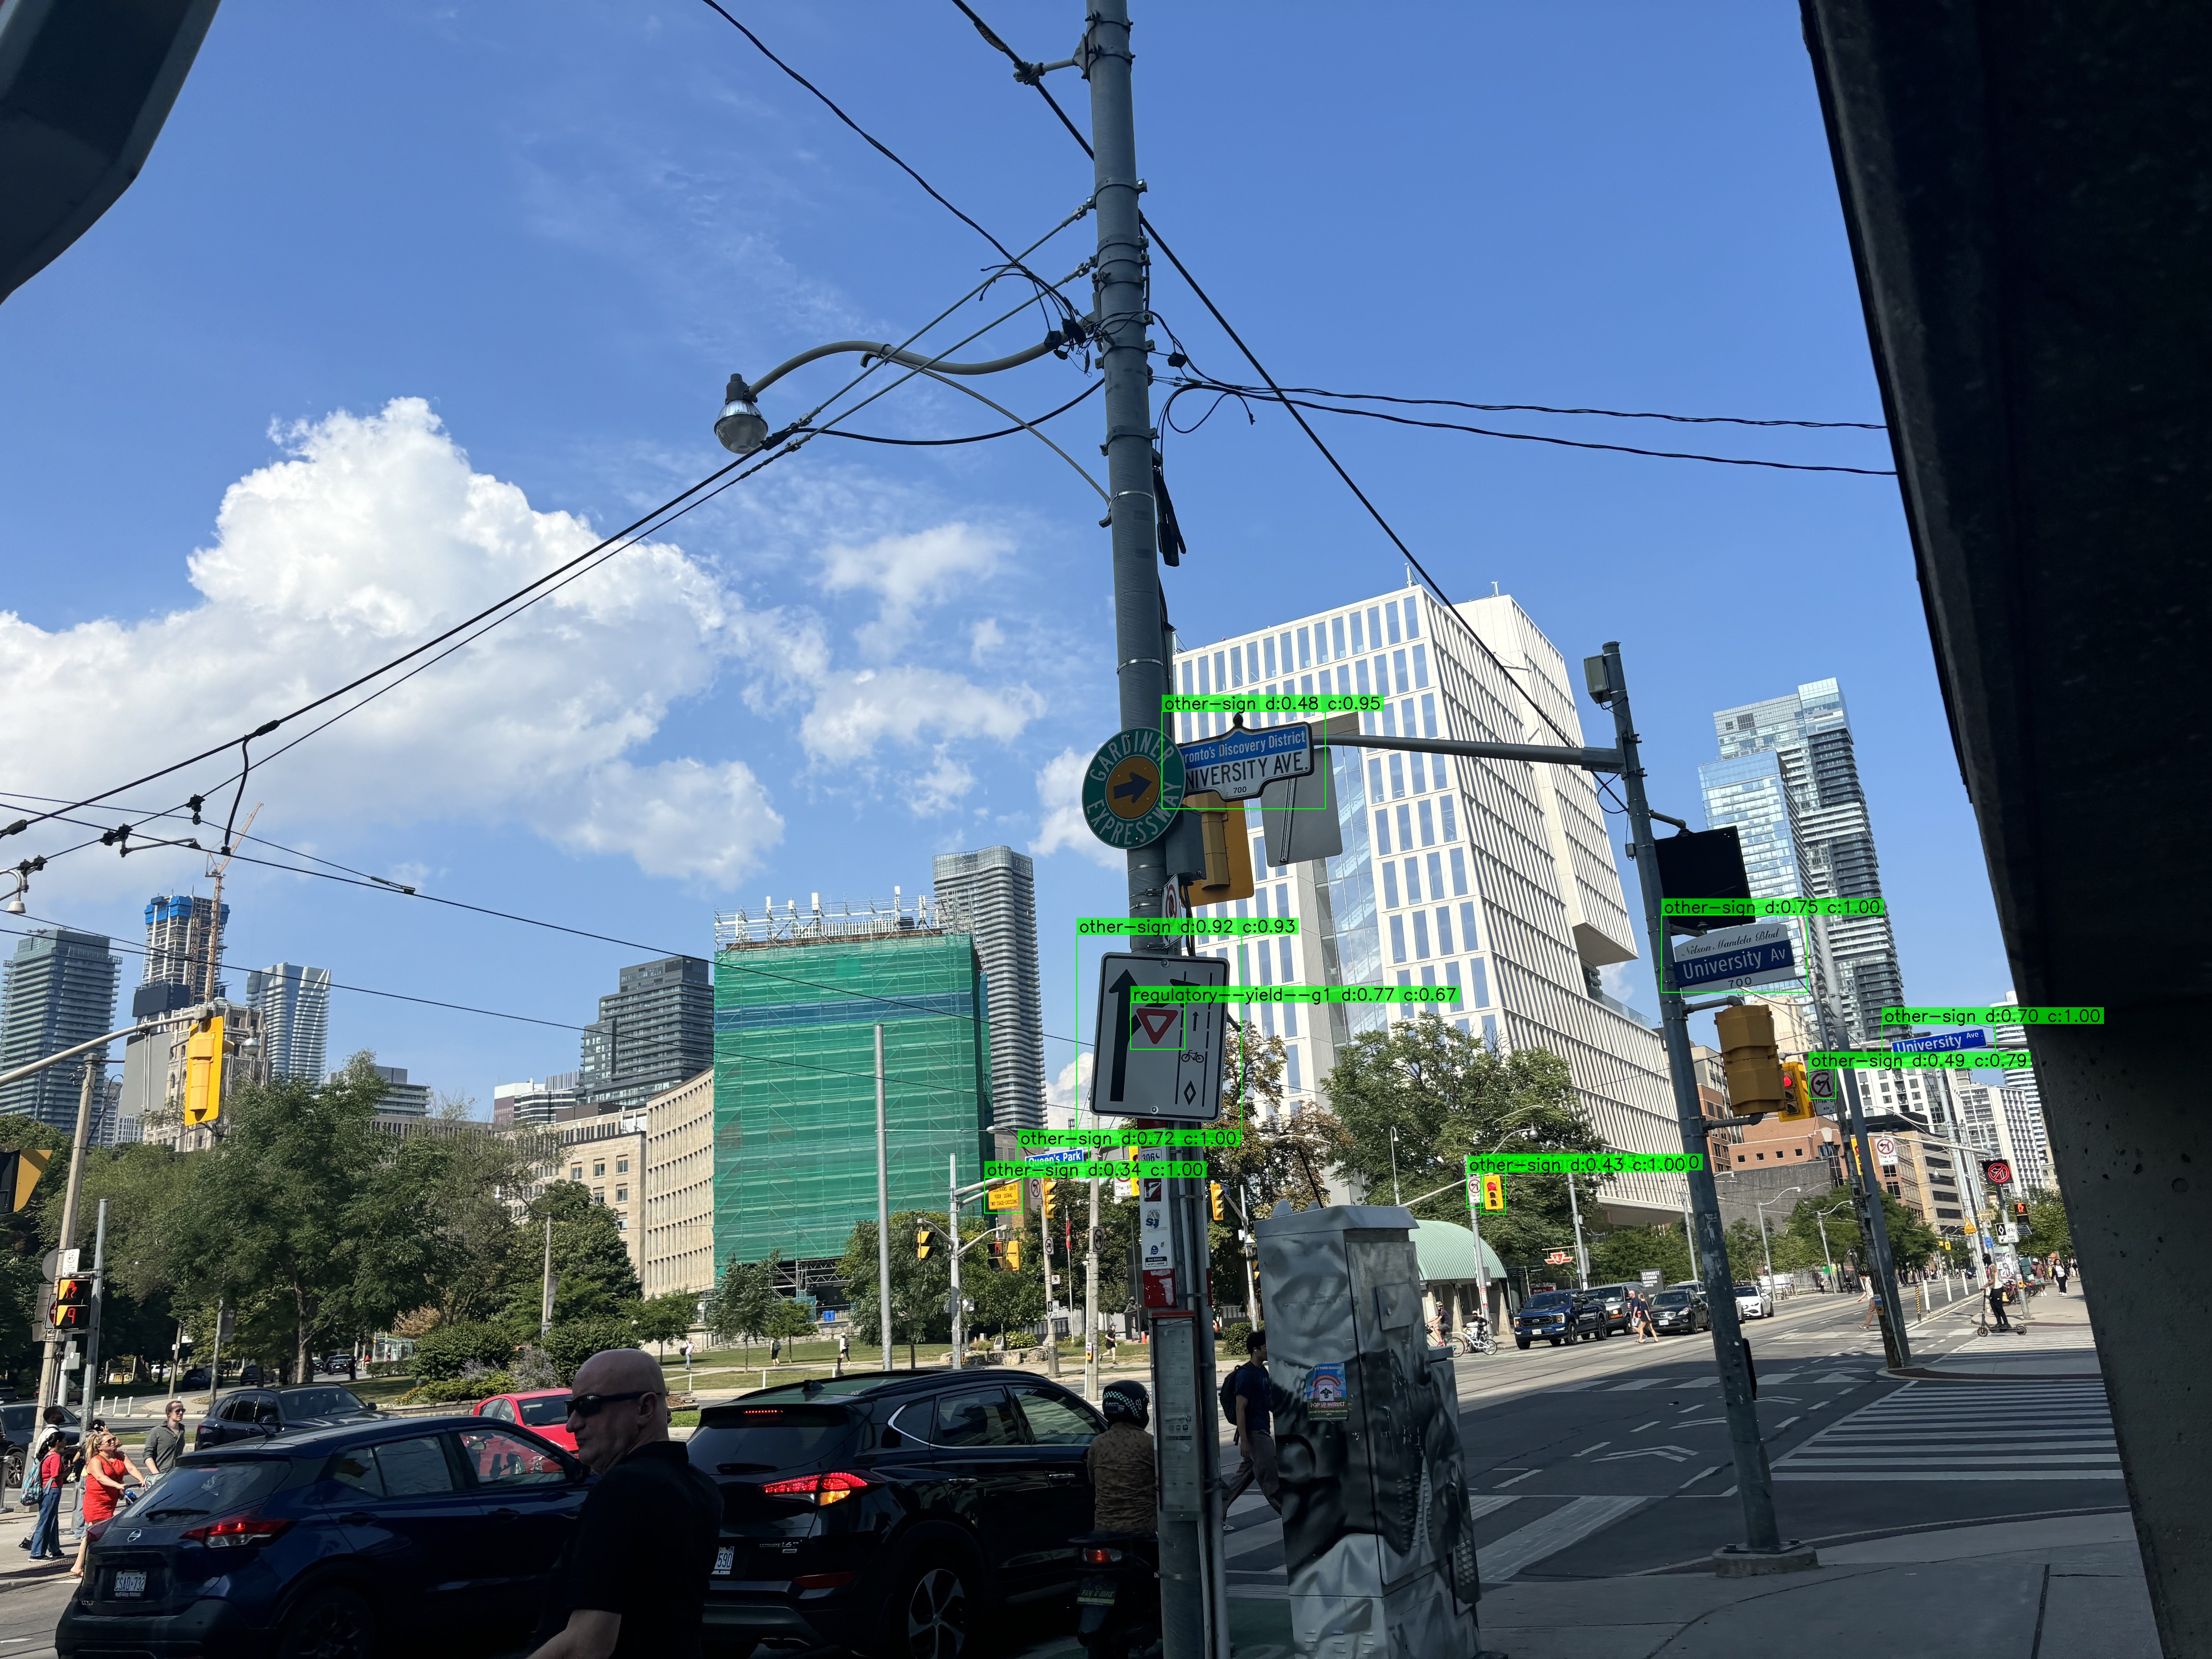
Inference output across several sign instances in a city street scene.
View original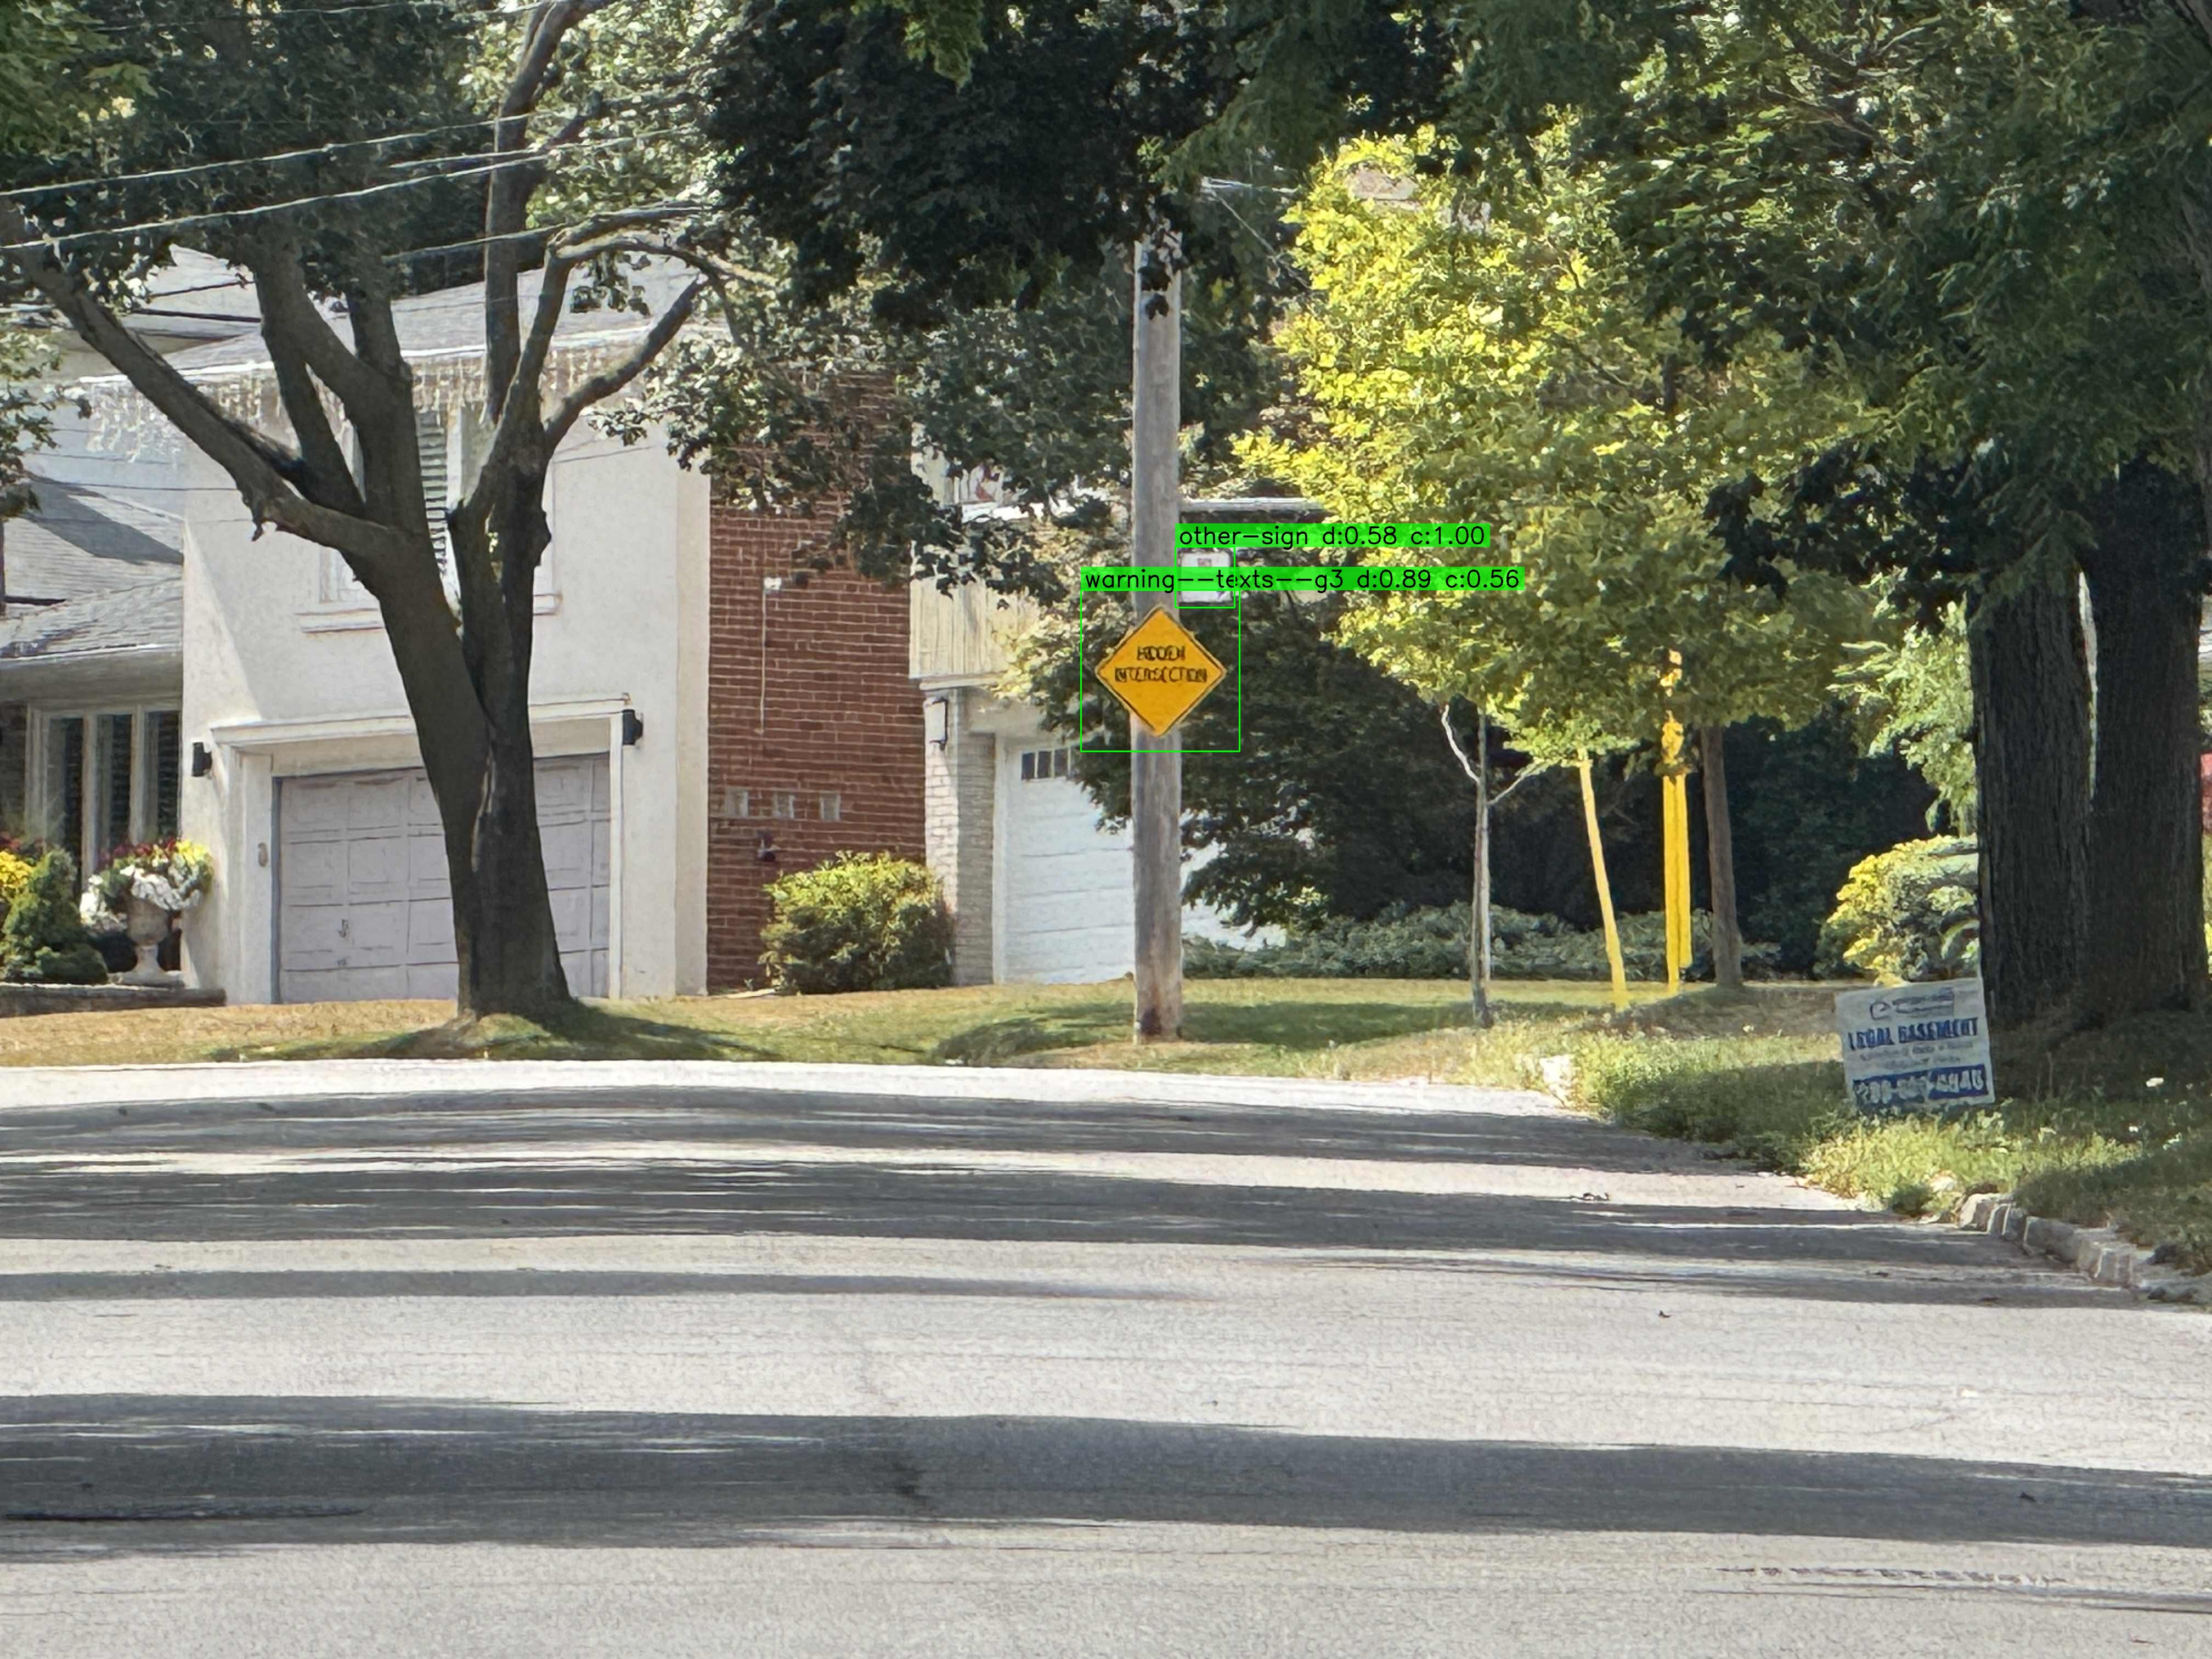
A further inference example, retaining the predicted label and confidence annotations.
View originalNext project / 01